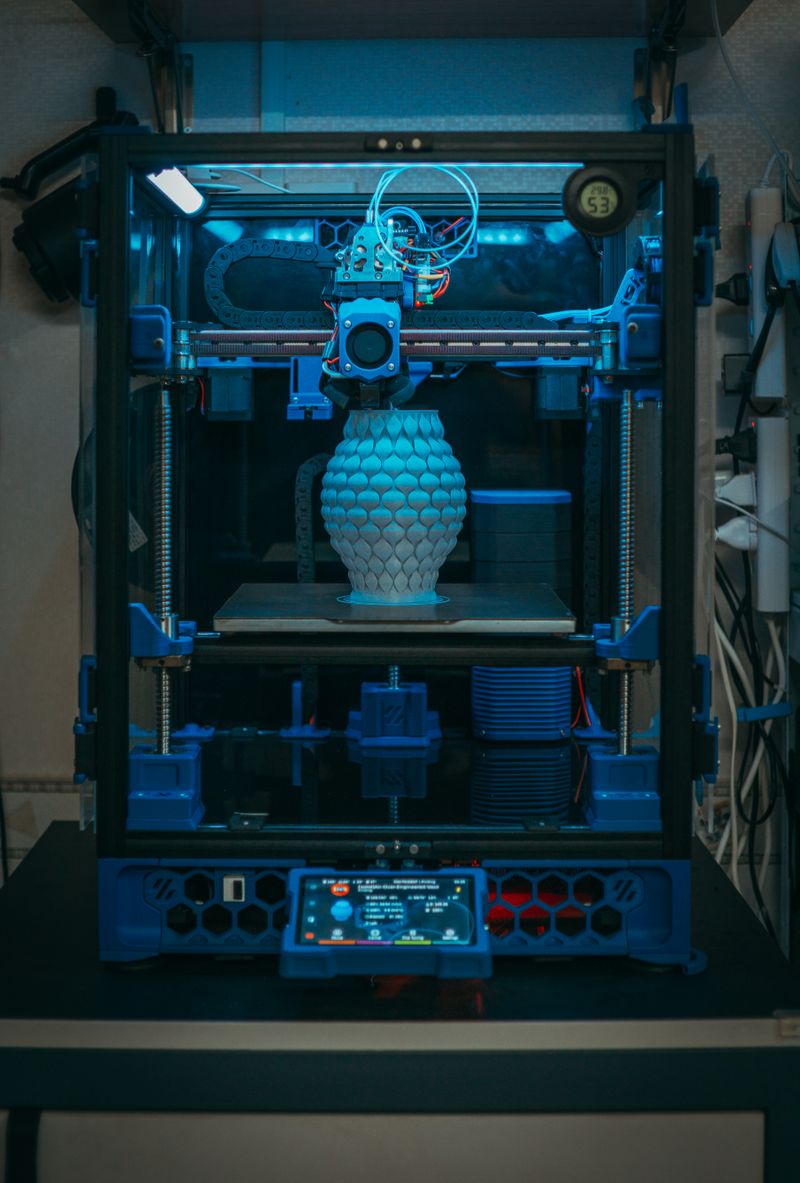
Project Overview
Jointed Arm Hardware, Printed as One System
An automation integrator needed a six-axis articulated arm — joint housings light enough to move fast, stiff enough to repeat position, and clean enough for daily production. Machined prototypes would take weeks and a stack of fixtures.
We printed the housings and joint rings in glass-filled SLS nylon — captured bearings, brass inserts at each servo mount, vapor-smoothed outer shells. The first full arm assembled four days after design freeze.
Challenge
Repeatability Without Machining
Each joint had to hold position under load through thousands of cycles. Thin-wall housings kept flexing in early FDM trials, and bearing seats printed out of round.
Approach
Printed for Cycles, Finished for Service
We shifted to SLS — zero supports, equal strength in all directions — tuned wall stock with the client team, and printed jigs so each joint pinned up with no hand-fitting.
Gallery
Build Snapshots
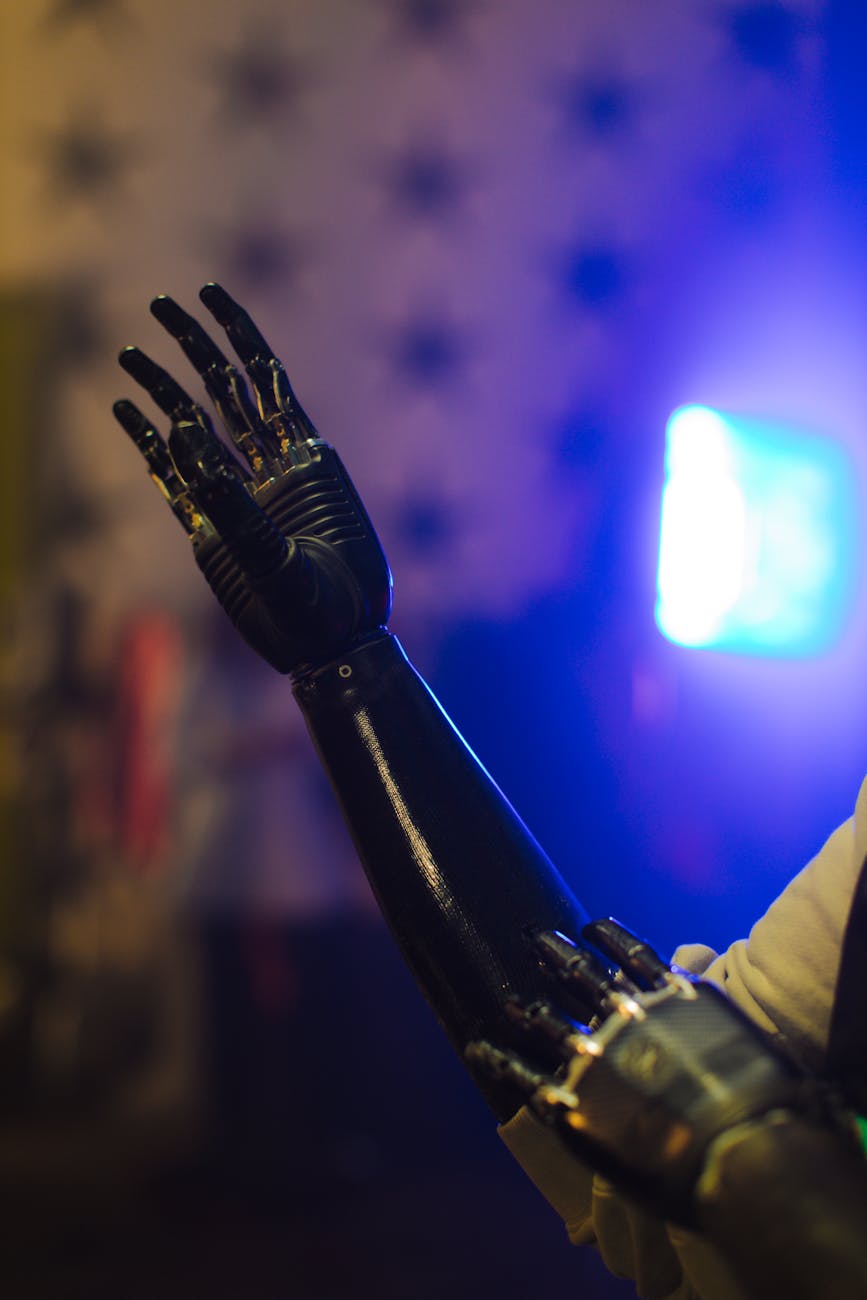

"The arm passed full cycle testing on its first build. That pulled our deployment schedule forward a quarter."
Dr. Lisa Clara Mendez — Robotics Engineer